
Imaging
Camera, lens and lighting matched to surface, working distance and motion.
Solutions · Robotics
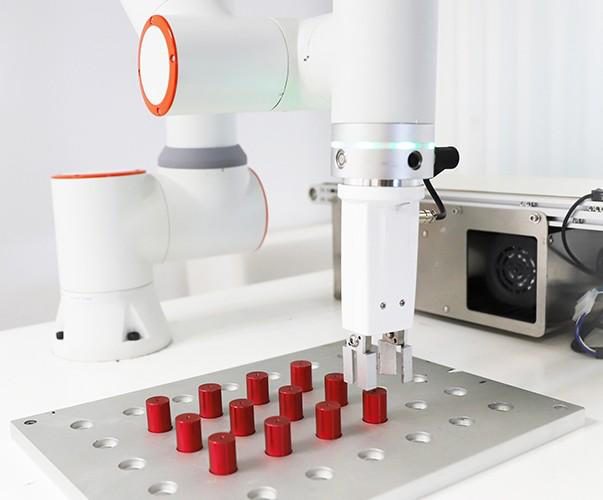
When operators manually find, turn and place parts, presentation determines how that work can be automated responsibly. Sedeco develops the vision chain from imaging and part pose to calibration, robot control and recovery.
Appropriate automation level
We choose the simplest approach that covers all permitted production variation. This reduces engineering, changeover time and maintenance without compromising reliability.
For parts on a known plane where position and rotation in the image plane are sufficient.
For visible parts with variable height, tilt or spatial orientation.
For randomly piled parts requiring grasp selection, reachability and collision checking for every pick.
From image to motion
Camera, lens and lighting matched to surface, working distance and motion.
Contour, feature, model or AI determines where and how the part lies.
Camera, robot and tooling are connected in a repeatable coordinate chain.
Pose, quality status and error codes are transferred reliably to robot and PLC.
Implementation
We define parts, presentation, tolerance, cycle time, gripper and exceptions. We then test extreme conditions, build the interface and validate normal production, changeovers and recovery.
Business case
Compare manual hours, ergonomic load, required capacity, rejects, changeover and operator interventions with camera, robot, gripper, engineering, safeguarding, training and maintenance. A representative trial provides the measurements for a defensible investment decision.
Feasibility
Share representative parts, current infeed, robot platform, gripper and required process outcome. We determine the trial needed and the appropriate automation level.